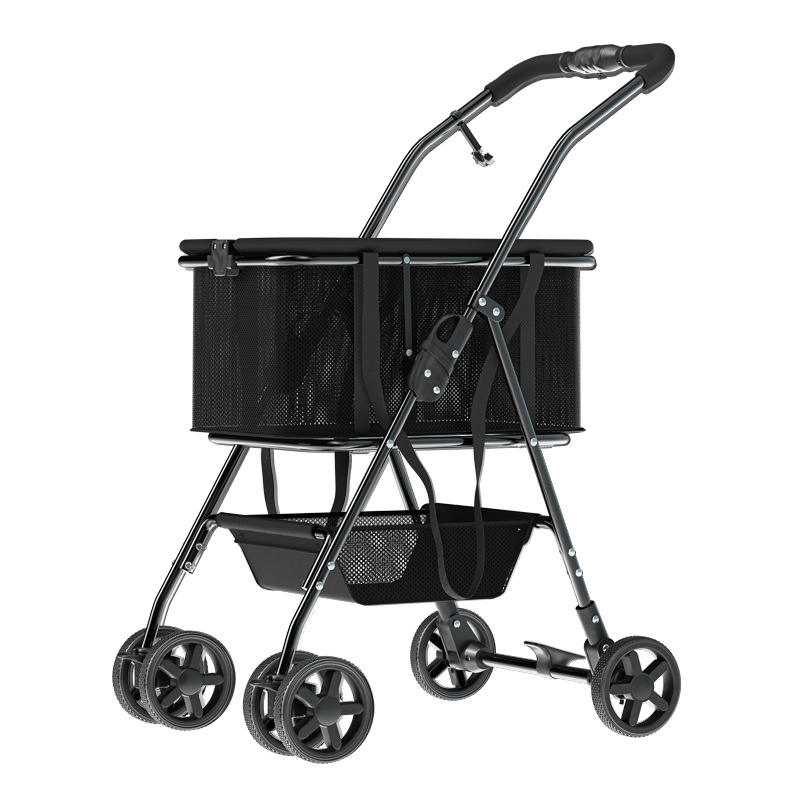
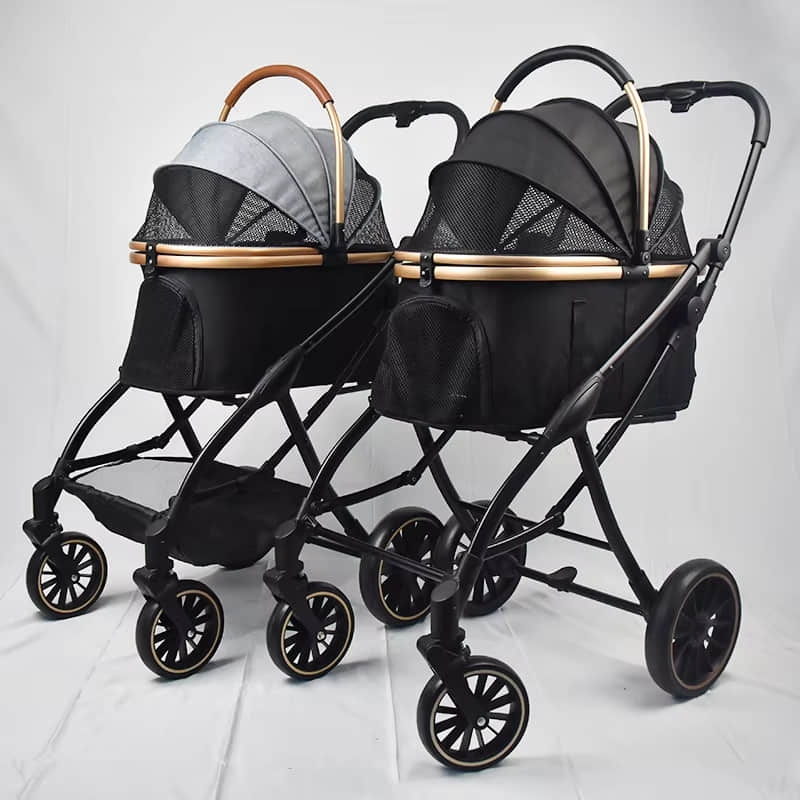
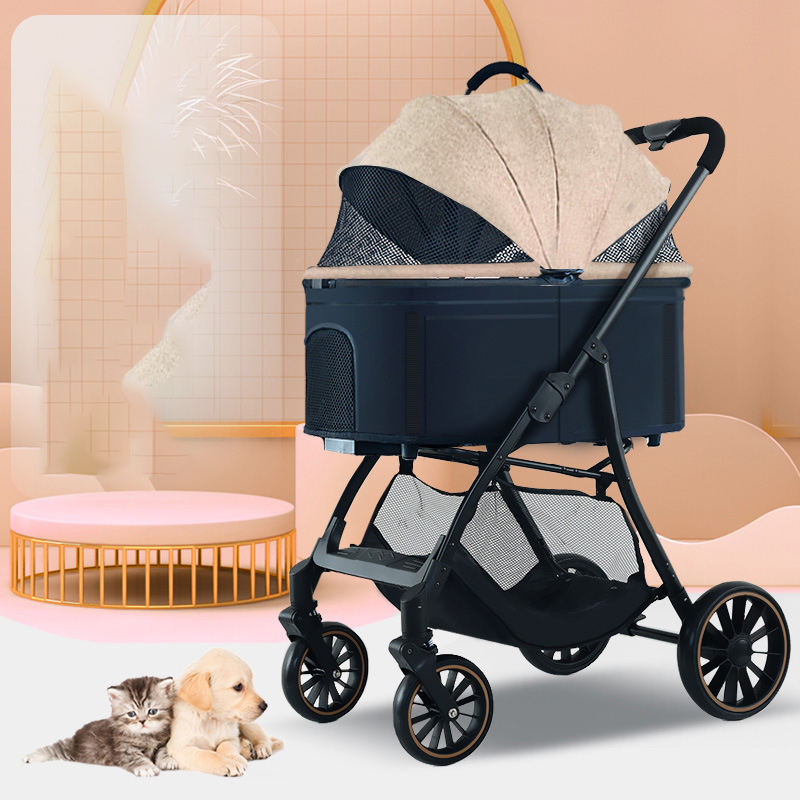
Designing the Braking System of a Pet Stroller Shopping Cart: Without Accidental Locking
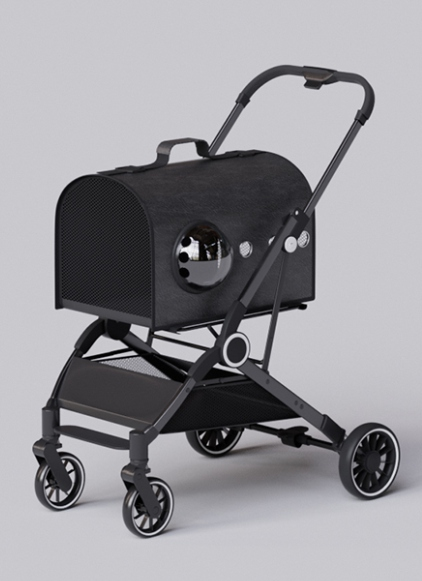
The modern pet stroller shopping cart is a marvel of urban utility, combining pet transportation with practical cargo carrying. Yet, one of its most critical—and often overlooked—components is the braking system. This system must perform a delicate balancing act: it must provide absolute, reliable stopping power on inclines to prevent a runaway stroller carrying both a beloved pet and groceries, while simultaneously being foolproof against accidental engagement during normal pushing. A failure in either direction compromises safety. Designing such a system requires a deep understanding of ergonomics, mechanical engineering, material science, and real-world user behavior. This article explores the principles, mechanisms, and material choices essential for creating a braking system that is both a reliable guardian on hills and a seamless companion on flat ground.
Understanding the Operational Demands and Failure Modes
Before diving into design, one must appreciate the unique use case. Unlike a bicycle brake, which is actively modulated, or a car parking brake, which is set and forgotten, a pet stroller shopping cart brake is used intermittently and often in hectic environments. The user might be holding a leash, a coffee, or a phone. The brake must be engageable and disengageable with minimal attention and effort.
Primary Requirements:
Positive Holding Power: The brake must securely hold the combined weight of the stroller, pet, and shopping load on the maximum recommended slope (often up to 15-20 degrees).
Accident Prevention: The mechanism must have a very low probability of engaging accidentally through bumps, kerb strikes, or inadvertent foot contact while pushing.
User-Friendly Operation: Engagement and disengagement should be intuitive, require low force, and provide clear tactile or auditory feedback.
Durability and Weather Resistance: It must function reliably after exposure to water, dirt, sand, and temperature variations.
Fail-Safe Tendency: The system should default to a "disengaged" state if a component fails, rather than locking unexpectedly.
Core Design Principles for a Dual-Objective Brake
1. The Principle of Deliberate Action
The brake actuator should require a specific, intentional action to engage. This is the primary defense against accidental locking. A simple downward press with a foot is common but prone to accidental engagement. Better designs incorporate a dual-action mechanism.
Example: A pedal that must be pressed and then slid laterally, or a two-pedal system where one pedal releases the other. This sequential action is unlikely to occur randomly.
Ergonomic Shape: The pedal should be recessed or shaped in a way that a foot brushing past it won't apply sufficient force or correct motion to trigger engagement.
2. Progressive Engagement & the "Rock-and-Lock" Feature
Instead of a binary on/off state, a high-quality brake can have a progressive feel. Initial pedal pressure creates light drag, signaling to the user that the brake is about to engage. Full pressure results in a positive, definitive lock. This prevents jarring sudden stops. Furthermore, the system should be designed to handle the natural "rocking" of a loaded stroller. On a slope, when the brake is engaged, the user may release the handle, causing the stroller to settle back slightly. The brake must have a self-energizing or compensating feature to take up this slack and maintain holding power, not dislodge.
3. Direct Force Transfer and Mechanical Advantage
The system should minimize flex and energy loss between the actuator and the braking surface. Using linkages or bowden cables is common, but each pivot and housing introduces potential play. The design must use leverage effectively. A small force from the user’s foot should be translated into a large clamping force at the wheel. This often means the actuator lever (pedal) is longer than the brake arm applying friction to the wheel.
4. Clear Feedback Systems
The user must have unambiguous confirmation of the brake’s status. This can be achieved through:
Tactile: A distinct "click" or "snap" into a detent position upon full engagement.
Visual: A brightly colored indicator (e.g., a red tab that appears when engaged).
Auditory: A satisfying, solid sound on engagement/disengagement.
Physical: The stroller should be immovable when the brake is correctly set.
Mechanism Archetypes: Analysis and Evolution
A. The Over-Center Toggle Lock (Common on Strollers)
This is a classic and effective design. A linkage passes over a "center" point; in the engaged position, the force of the pet stroller shopping cart trying to roll actually pushes the linkage harder into the locked state. This is highly reliable for holding but can sometimes be too easily engaged with a simple downward kick.
Optimization for Safety: Combine the over-center mechanism with a dual-action pedal. The first action (press down) tensions the system, the second (slide forward) pushes it over-center. Disengagement is a simple reverse-action kick-back on the pedal.
B. Disc Brake Systems (Adapted from Cycling)
A small stainless steel disc mounted on the wheel hub, with a caliper activated by the foot pedal.
Pros: Excellent, progressive braking power; works well in wet conditions; less affected by wheel rim true.
Cons: More complex, heavier, and potentially more expensive. Risk of bending the disc in collisions.
Anti-Lock Design: To prevent accidental locking, the caliper could be designed to require a minimum threshold force before any braking occurs, or use a dual-pivot design where the first part of the pedal travel retracts a safety pin before the pads contact the disc.
C. Drum Brake Systems
A sealed drum within the wheel hub, with brake shoes that expand outward.
Pros: Very powerful, completely protected from weather and debris, long-lasting.
Cons: Heavier, can suffer from heat buildup on long descents (less relevant for strollers), and disassembly for maintenance is more complex.
Anti-Lock Design: The engagement mechanism can be a rotary cam. Accidental linear force from a bump is unlikely to rotate this cam into the engaged position.
D. Positive Wheel-Lock (Spoon Brake) with Safety Gate
This is the simplest form: a metal bar or "spoon" is pushed directly against the tire tread or a dedicated striker on the wheel.
Pros: Simple, direct, and very strong.
Cons: Can wear the tire; prone to accidental engagement if the actuator is poorly shielded.
Optimization: Enclose the actuator in a hooded "gate." To engage, the user's foot must first hook under the gate and lift slightly (disarming the safety), then press down. This two-motion process is very effective at preventing accidents.
Material Selection for Durability and Performance
The braking system lives in a harsh environment—close to the ground, subject to water, mud, road salt, and constant mechanical stress.
1. For Brake Pads/Shoes/Friction Surfaces:
Sintered Metal: Excellent for disc brakes. Offers strong braking in wet and dry conditions, durable, but can be noisy and wear down rotors faster.
Organic/Resin Compounds: Softer, quieter, and gentler on mating surfaces. Good for dry conditions but may wear faster when dirty or wet. Suitable for drum brakes or direct wheel-contact systems.
Rubber with Fabric/Cord Reinforcement: For simple spoon brakes against a tire, a durable, high-friction rubber compound is key. It must resist hardening from UV exposure.
2. For Structural Components (Levers, Linkages, Housings):
Stainless Steel (304 or 316): Ideal for all critical pivot pins, springs, and cables. Its corrosion resistance is paramount. Music wire springs offer excellent fatigue life.
Hard-Coated Aluminum Alloys (e.g., 6061-T6 with anodizing): Good for levers and caliper bodies where weight is a concern. The hard coat adds wear resistance.
Engineering Polymers (Glass-Filled Nylon, POM/Acetal): Excellent for pedal bodies, housing parts, and low-stress linkages. They are corrosion-proof, can be molded into complex, ergonomic shapes, and operate quietly. POM is particularly good for low-friction pivot bushings.
3. For Cables and Housings (if used):
Stainless Steel Strand Core with PTFE Lining: Provides smooth operation and resists rust. Housing should be tightly coiled and sealed with end caps to prevent water ingress.
Integration, Testing, and Real-World Validation
A brilliant mechanism can fail if poorly integrated.
Positioning: The brake actuator should be positioned on the rear axle or between the rear wheels, accessible from behind the stroller without reaching under. Its location must be intuitive.
Symmetric vs. Single-Wheel Braking: Engaging brakes on both rear wheels is standard for maximum holding power. The mechanism should be designed to engage both sides equally to avoid pulling the stroller to one side.
Testing Protocol: The design must be validated through brutal testing:
Slope Hold Test: Load stroller to maximum capacity, place on a 20-degree incline, engage brake, and measure any creep over 30 minutes.
Accidental Engagement Test: Push the stroller at walking/jogging speed over cobblestones, kerbs, and gravel, deliberately striking the brake area with feet. It must not lock.
Cycle Testing: 10,000+ engage/disengage cycles, followed by performance re-testing.
Environmental Testing: Submersion in water, coating in sand/mud, and temperature cycling from -10°C to 50°C.
Conclusion
Designing the braking system for a pet stroller shopping cart is an exercise in empathetic engineering. It requires anticipating the distracted, multi-tasking user and the very real consequences of failure on a hill. The optimal system is not necessarily the most powerful, but the most intelligently integrated.
It will likely feature a dual-action engagement mechanism—such as a lift-and-press or press-and-slide pedal—that makes accidental locking a near impossibility. It will employ a direct, robust linkage or a sealed, weather-resistant drum or disc system to provide fail-safe holding power. Its materials—stainless steel, hard-coated alloys, and advanced polymers—will be chosen for lifelong corrosion resistance and wear performance. Most importantly, it will communicate clearly with the user through a satisfying click and a clear visual cue, building trust that when set, the stroller—and the precious living cargo within—will stay securely in place.
Ultimately, a well-designed brake is an invisible guardian. It provides peace of mind on a slope without ever being a nuisance on the flat, seamlessly blending absolute safety with effortless usability. In the world of pet product design, such thoughtful engineering is the true mark of quality, ensuring that every journey, whether to the park or the supermarket, ends safely and stress-free.
For more about designing the braking system of a pet stroller shopping cart: without accidental locking, you can pay a visit to Hechen PDLC Smart Film Manufacturers for more info.